Boston Dynamics gives Atlas a new four-fingered hand built for factory work
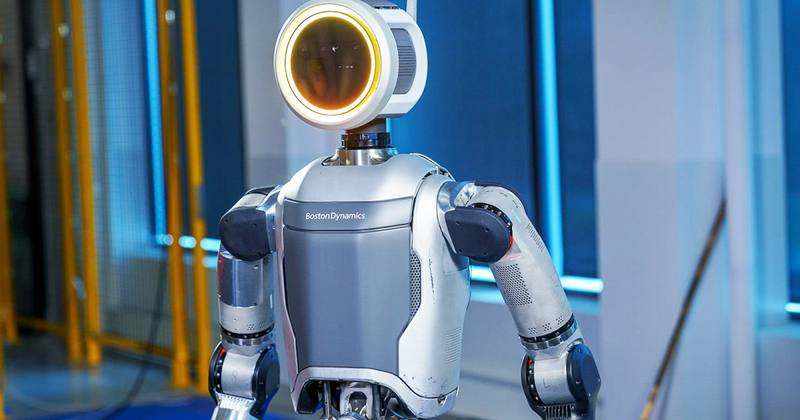
Boston Dynamics has unveiled a redesigned hand for its Atlas humanoid: 13 degrees of freedom, four fingers — no pinky — and direct actuation, nearly doubling the 7 degrees of freedom of the previous generation. The company announced the new hand on October 1, describing it as hardware built for real work rather than human mimicry.
The design is a deliberate tradeoff. "We didn't set out to build a complicated hand, but instead a reliable one capable of using tools," the company said. Alberto Rodriguez, Boston Dynamics' director of robot behavior for Atlas, said the team dropped the pinky after spending a day with their own pinkies taped to their ring fingers — the extra finger wasn't worth the added complexity and power draw.
Every joint is directly actuated with a single actuator type, fully encapsulated, with no fragile cables crossing joints. The hand can splay its fingers — a motion beyond human capability that the team says reinforcement learning can exploit. It was designed from the start for high-fidelity simulation, so skills learned in simulation transfer to the real robot through sim-to-real RL.
The goal is no longer just grasping objects but manipulating them: pinch and tripodal grasps, plus triggered tool grasps for drills, torque drivers, grinders, nail guns, and welding torches. In the launch video, Atlas twirls a drumstick, handles two golf balls in one hand autonomously, and operates a power drill.
The timing matters. The hand arrives about a week after Boston Dynamics and Hyundai opened the Robotics Metaplant Application Center in Georgia, where Atlas is being trained for automotive manufacturing. Hyundai plans to deploy up to 25,000 Atlas robots across its plants and build a US facility capable of producing 30,000 robots a year. Rodriguez put the manufacturing ambition bluntly: the team is now figuring out what must change "if we want to make 100,000 of these hands a year."